
This repository provides an implementation of the paper:
Leveraging Symmetry in RL-based Legged Locomotion Control
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2024
paper / project page
Note
All three methods of the paper, PPO, PPO with symmetry data augmentation (PPOaug) and PPO
with an equivariant actor-critic (PPOeqic), are now implemented on the
extras branch of rsl_rl. To make
them easy to use, this branch is a small example built on
mjlab: it trains mjlab's Unitree G1 flat-terrain
velocity task with each of the three methods. The original Isaac Gym code is on the
isaacgym/main and
isaacgym/dribbling
branches.
Install uv, then:
git clone https://github.com/HybridRobotics/SymmLoco.git
cd SymmLoco
uv syncTasks:
VelocityFlat-G1-PPO: PPO baselineVelocityFlat-G1-PPOaug: PPO with symmetry data augmentationVelocityFlat-G1-PPOeqic: PPO with an equivariant actor-critic
Train:
uv run train <TASK_ID> --env.scene.num-envs 4096 --agent.seed <SEED>Play a checkpoint from a W&B run:
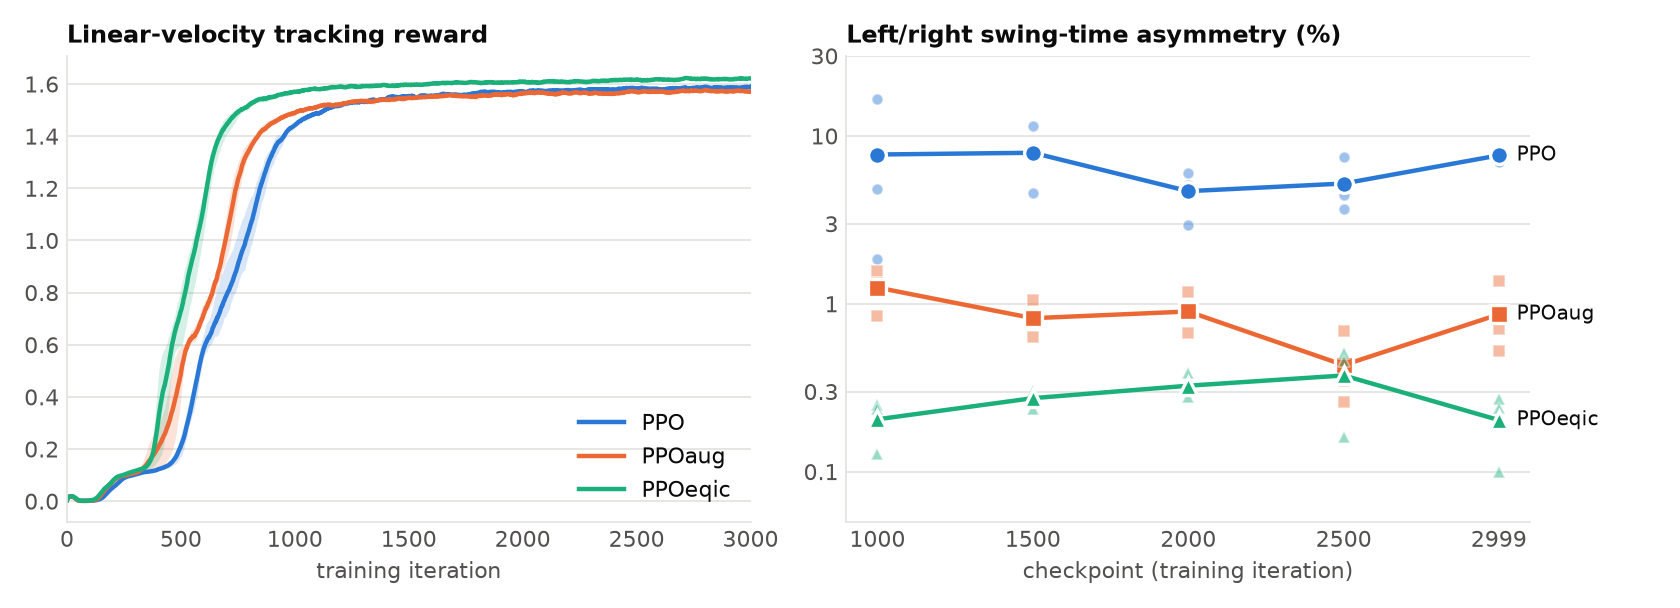
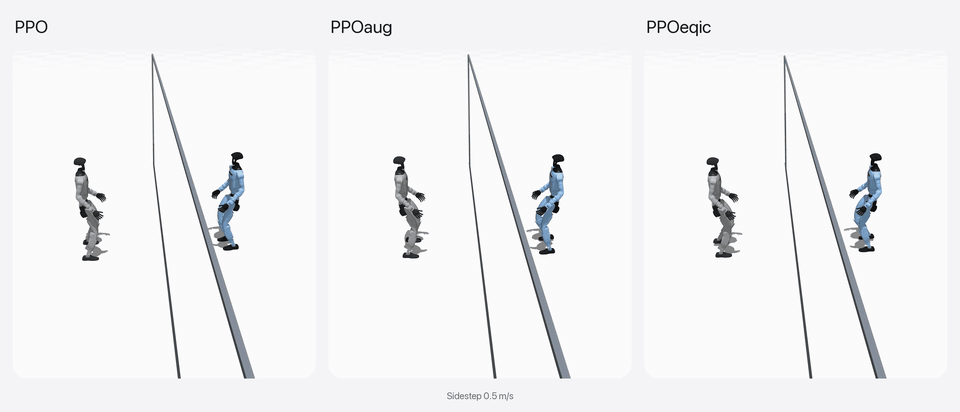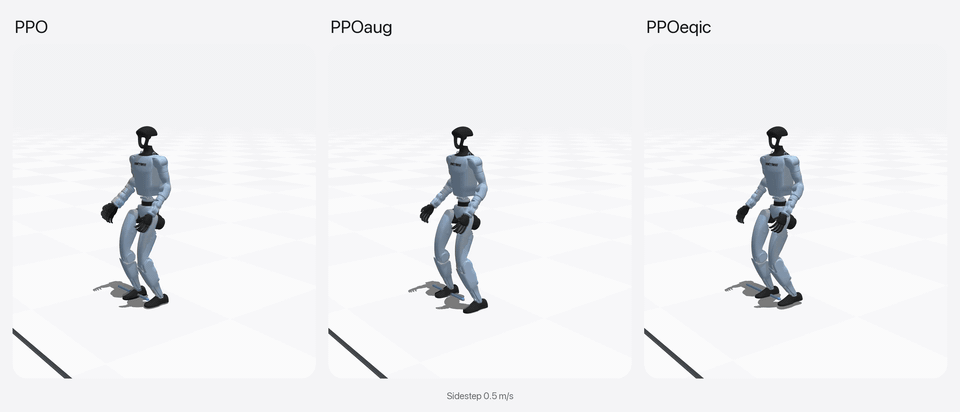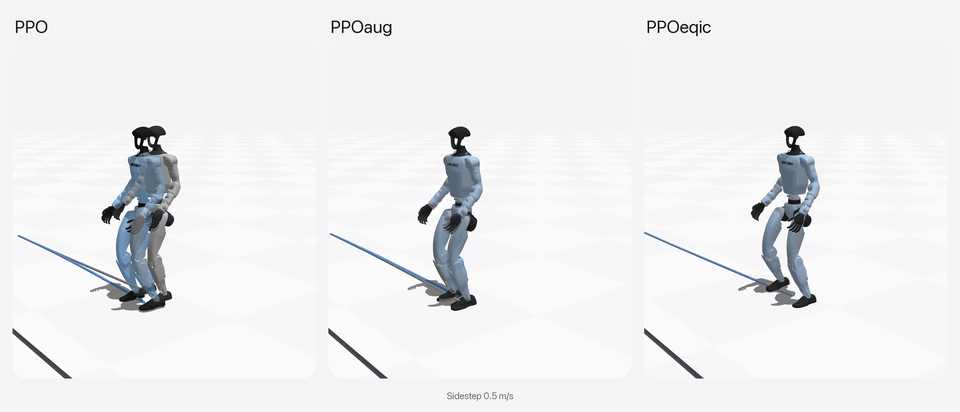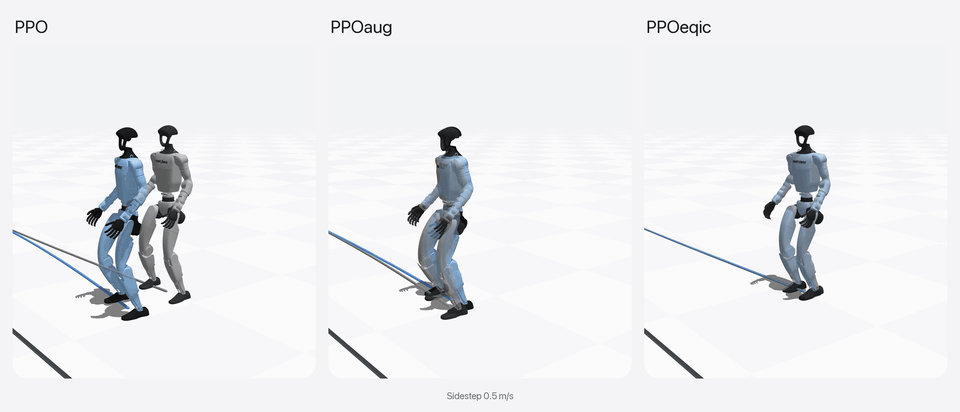
uv run play <TASK_ID> --wandb-run-path <ENTITY>/<PROJECT>/<RUN_ID>Unitree G1, 3 seeds per method, 4096 environments, 3000 iterations.
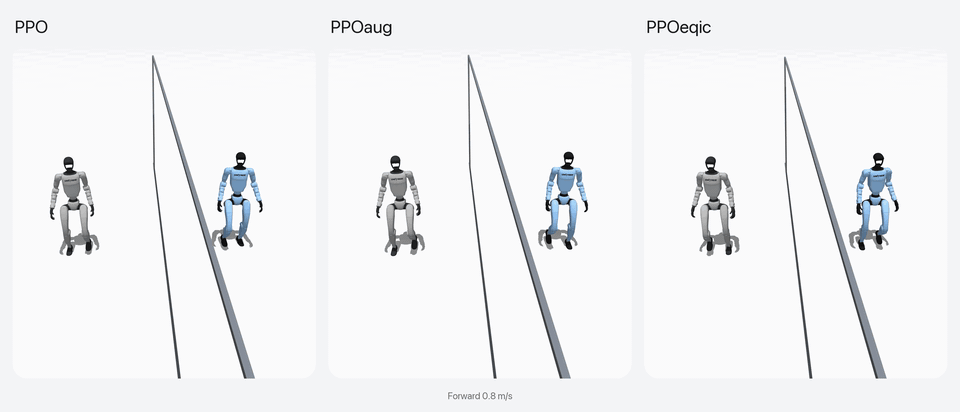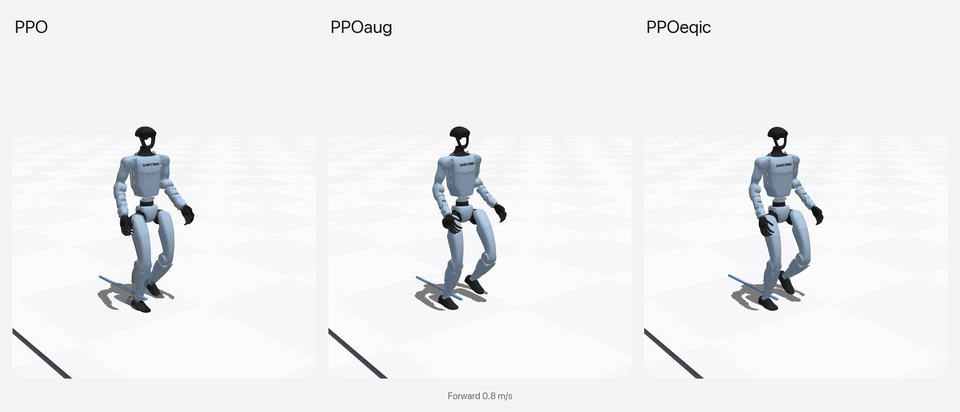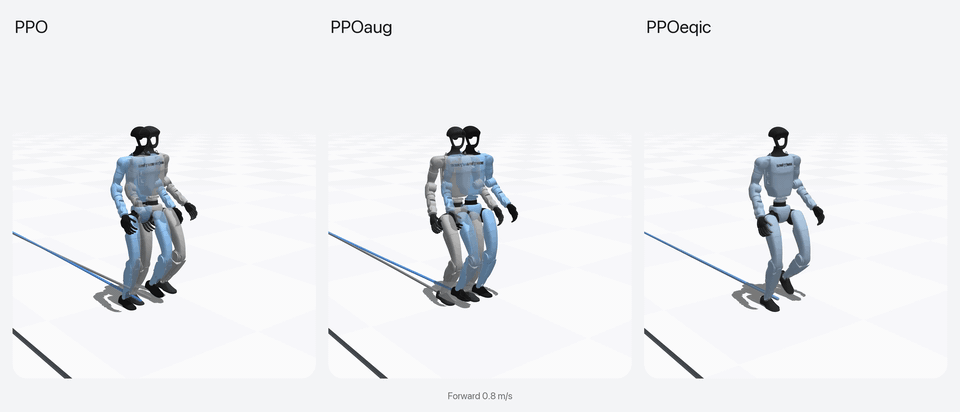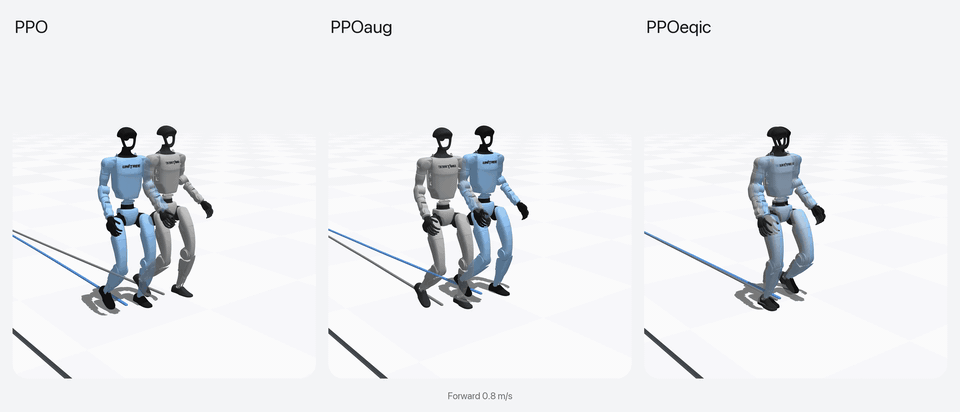
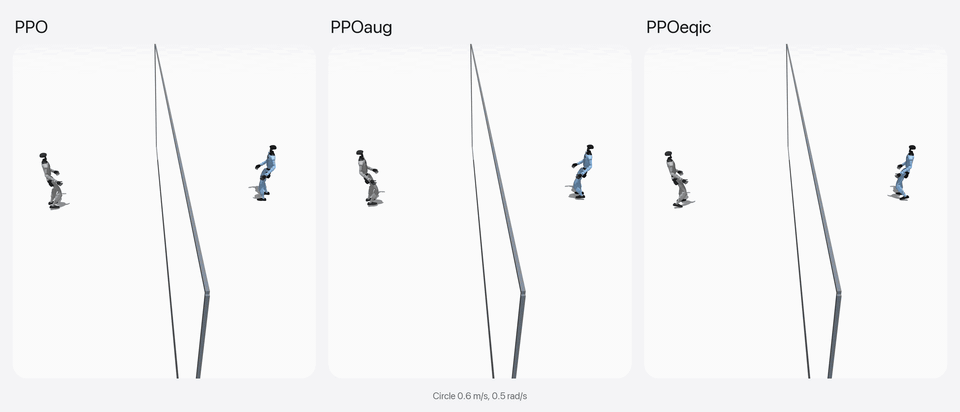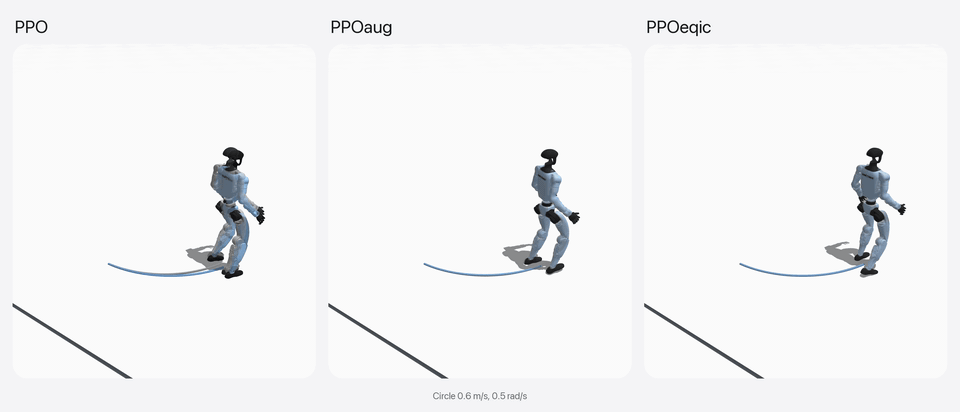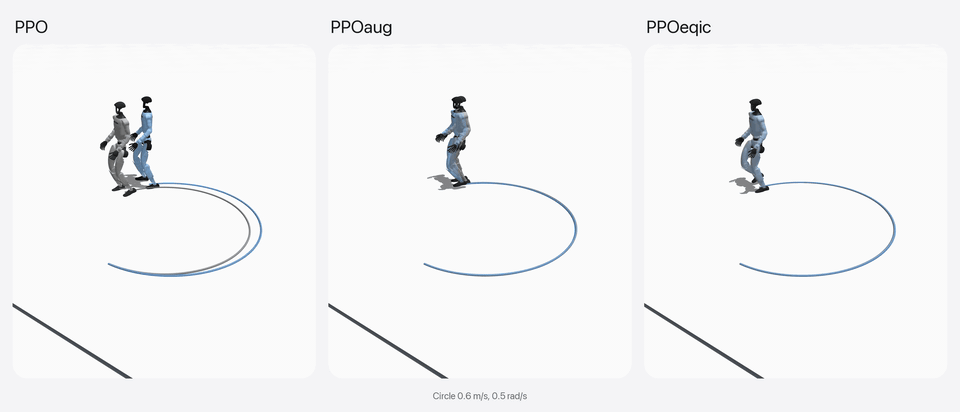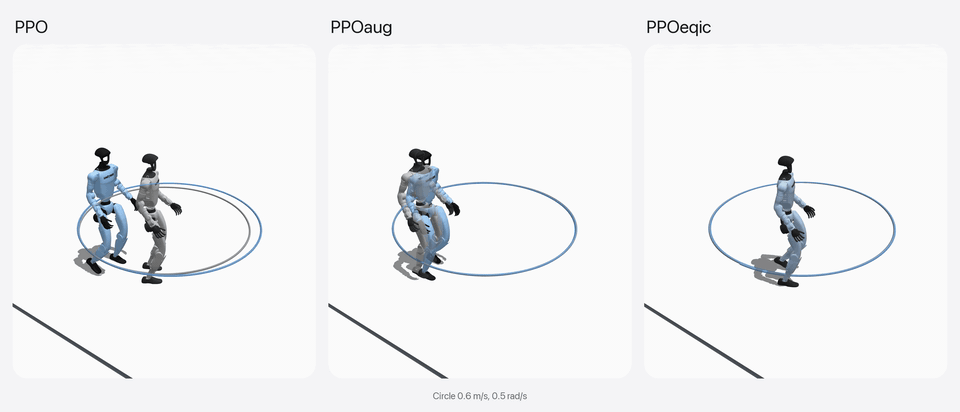
A second robot (blue) walks behind a half mirror and gets the mirrored command. In the mirror, the reflection of the first robot (silver) falls on top of it; a symmetric policy keeps the two together. Click a clip for the full-resolution video.
@inproceedings{su2024leveraging,
  title={Leveraging Symmetry in RL-based Legged Locomotion Control},
  author={Su, Zhi and Huang, Xiaoyu and Ordo{\~n}ez-Apraez, Daniel and Li, Yunfei and Li, Zhongyu and Liao, Qiayuan and Turrisi, Giulio and Pontil, Massimiliano and Semini, Claudio and Wu, Yi and Sreenath, Koushil},
  booktitle={2024 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
  year={2024}
}